top of page
INVERSE KIN-ARACHNIDS

kill it with fire

spider community

spider disaster
kill it with fire
1/3
Inverse Kin-Arachnids is a game prototype exploring procedural animation through inverse kinematics. This project was completed in about a week alongside my partner Bill Dang. It was developed in Unity with Daniel Erdmann's FastIK system.
My contributions to the project were largely focused on defining the procedural locomotion of both 2 and 4-legged spiders. The animation is performed in the following stages:
-
Raycast downwards to locate the ground
-
Calculate the distance the leg needs to step
-
Lock feet in place when not stepping
-
Allow diagonally-opposite legs to step together
-
Rotate the spider's body based on the height of each leg
You can download our project on itch.io or check out our GitHub.

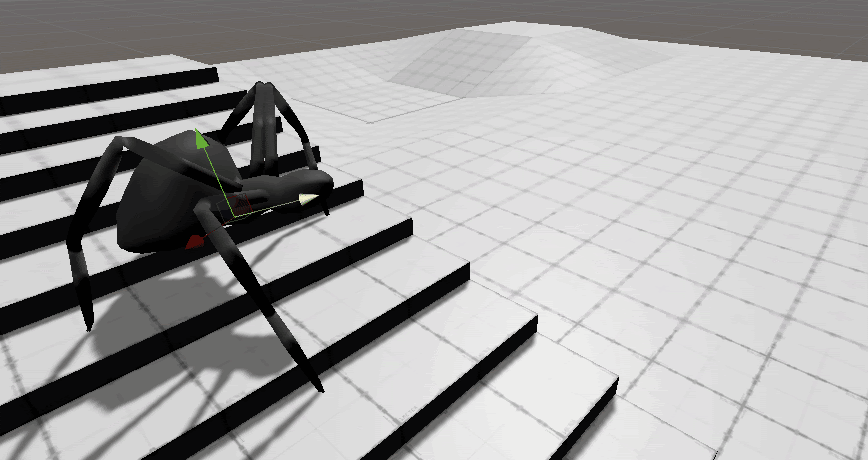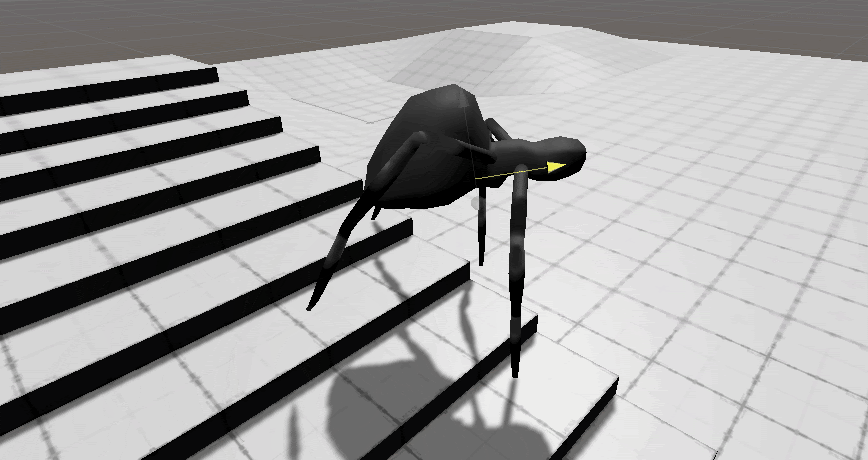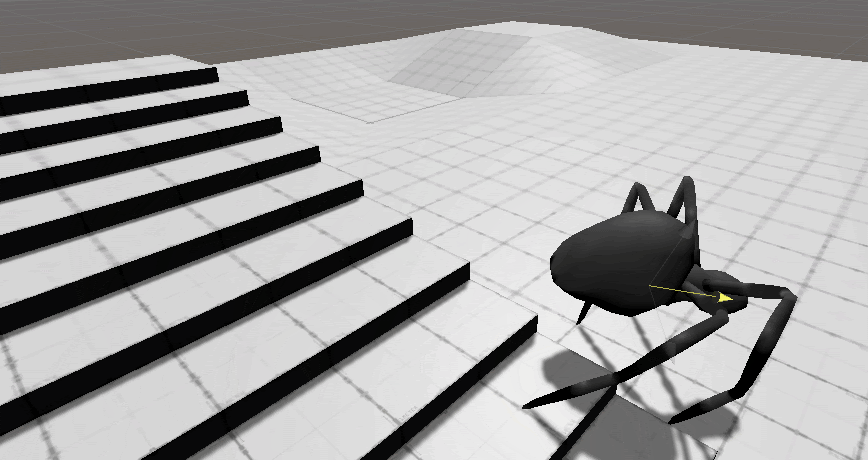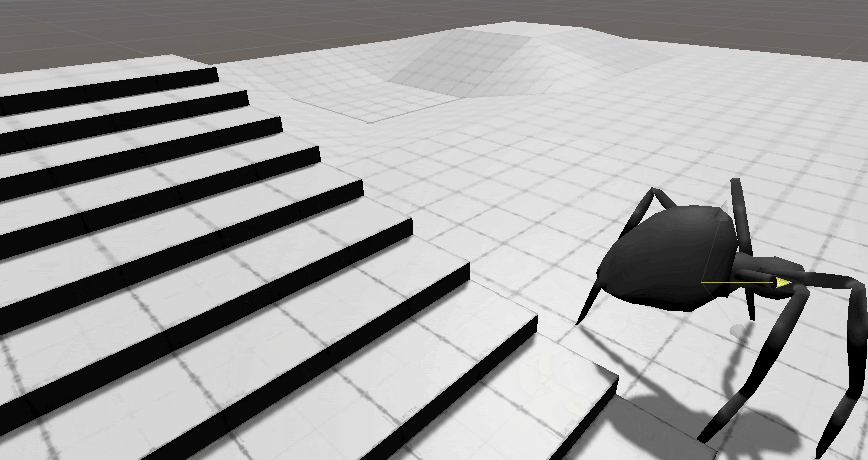
Gameplay
bottom of page